
Viam Debuts Box-Opening Robot at IROS 2026
Viam Debuts Box-Opening Robot at IROS 2026
PR Newswire
PITTSBURGH, Sept. 22, 2026
Trained on 125 teleoperated demonstrations collected in about five hours, BoxBot pairs image-based visual servoing with an open source VLA, no custom architecture required, on one data path built on Viam.
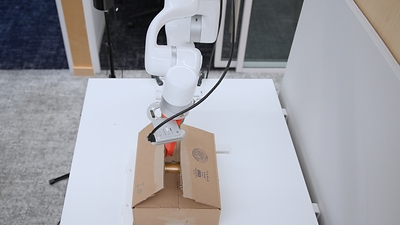
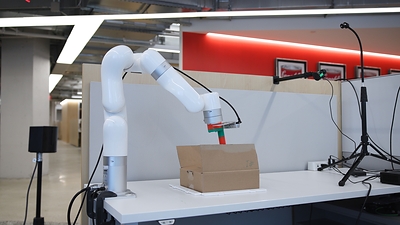
PITTSBURGH, Sept. 22, 2026 /PRNewswire/ -- Viam, the software platform for robotics, will debut BoxBot at IROS 2026, one of the world's leading robotics research conferences held in Pittsburgh from September 27 through October 3. BoxBot is an ongoing Viam research project: a robot arm that opens taped cardboard boxes using image-based visual servoing to cut the tape and a vision-language-action (VLA) model, trained on human demonstrations, to open the flaps.
A hybrid approach to manipulation
BoxBot specifies what it can and learns what it can't:
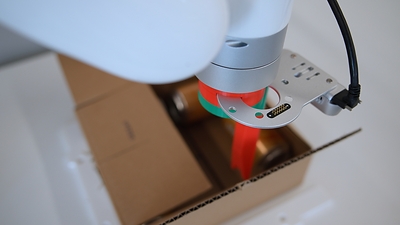
- Visual Servoing: No two sealed boxes are alike, so the robot uses image feedback to guide the cutting tip to tape seams that are typically 1 to 2mm wide.
- Learned Policy (VLA): A fine-tuned SmolVLA model handles the deformable, contact-rich task of peeling open and adjusting four box flaps.
Both systems run as native services on the same machine, with the VLA policy inferring locally on an NVIDIA Jetson Orin Nano via Viam's ML model service.
Less time on data plumbing, more time on research
Researchers often spend weeks building teleop rigs, syncing cameras to joint states, and formatting episodes for training, then rebuild it all for the next arm. On Viam, that capture layer already exists, making it easy to add an input device as a module, record synced episodes, and copy a config fragment to stand up another station.
Two Viam engineers collected BoxBot's 125 demonstrations in about five hours over four days using a VR controller. Viam synced the arm data and two camera streams to the cloud, the team fine-tuned SmolVLA with LeRobot on Hugging Face Jobs, and deployed the policy back to the robot. No custom model architecture, no task-specific engineering: the base model and 125 episodes were enough for a working policy.
The code and dataset are open on Hugging Face at https://huggingface.co/viamrobotics, so researchers can train on them, benchmark against BoxBot, or reproduce the setup. See BoxBot in development at Viam's NYC robotics lab, here.
At the booth
IROS attendees can see BoxBot run, drive the arm themselves, and record data on a separate station:
- BoxBot: Watch the arm cut the tape seam and open the flaps.
- VR teleoperation station: Control the arm using the same VR setup that produced BoxBot's training data.
- SO-101 leader-follower station: Move a leader arm, watch the follower mirror it, record and replay an episode, and see the synced data in the Viam app.
"The question isn't whether to use a VLA, it's where," said Shannon Bradshaw, Ph.D., SVP of Product and Education at Viam. "Learned policies are the right tool for contact-rich manipulation tasks that are hard to model analytically, and methods like visual servoing enable precise solutions in dynamic environments. This robot also uses classical motion planning for other elements of the application. With many frameworks, this would require extensive ad hoc scripting to bring everything together in one application. The Viam platform provides an integrated solution that enables us to combine the hardware, software, and models this robot uses in a coherent solution we can easily iterate on, updating components as needed and adding new ones as we build new capabilities. Our implementation is publicly available, so robotics and physical AI researchers can check our work or build on it."
Viam, the software platform for robotics, runs BoxBot's hardware abstraction, visual servoing, computer vision, data capture, and edge ML deployment as services behind one set of APIs. Developers connect hardware in JSON, write logic in Python, Go, or TypeScript, and pull modules from the Viam Registry. ROS 2 teams can run Viam alongside existing robots through the viam-ros2-integration module.
IROS attendees can visit Viam at Booth 828. To book a technical demonstration or meeting with the Viam engineering team, reach out to Viam's SVP of Product and Education, Shannon Bradshaw, at team@viam.com.
About Viam
Viam is the software platform for building, deploying, and managing robotics applications. With Viam, engineers, startups, and large enterprises can develop for the physical world the way they develop anything else. Viam works with teams across manufacturing, marine, climate, logistics, entertainment, and more. Founded in 2020 by MongoDB co-founder and former CTO Eliot Horowitz, Viam has its headquarters and robotics lab in New York City. viam.com
Media Contact:
Christopher Farrell
Beginners | chris@wearebeginners.co

SOURCE Viam, Inc.
The articles, information, and content displayed on this webpage may include materials prepared and provided by third parties. Such third-party content is offered for informational purposes only and is not endorsed, reviewed, or verified by Morningstar.
Morningstar makes no representations or warranties regarding the accuracy, completeness, timeliness, or reliability of any third-party content displayed on this site. The views and opinions expressed in third-party content are those of the respective authors and do not necessarily reflect the views of Morningstar, its affiliates, or employees.
Morningstar is not responsible for any errors, omissions, or delays in this content, nor for any actions taken in reliance thereon. Users are advised to exercise their own judgment and seek independent financial advice before making any decisions based on such content. The third-party providers of this content are not affiliated with Morningstar, and their inclusion on this site does not imply any form of partnership, agency, or endorsement.
Popular

4 Stocks to Buy for the Long-Term While They’re Still Undervalued

Why This Vanguard ETF Is One of the Best

6 ETFs To Diversify Away From AI

The Best AI Stocks to Buy Now


 United States